Student Projects
Note: If you are an international student interested in doing an internship, research stay, or your senior/master thesis in our lab, check the information available in Open Positions.
If you are an undergraduate or graduate student from UMA interested in space robotics, below you will find the latest available projects in our lab.
If you would like to do a project with us but couldn’t find a suitable project, all projects are already assigned, or you have a project idea you’d like to pursue in our lab, please email us explaining your proposed idea.
Please note that some projects are exclusively available for  , while others are open for
 or both. Some of our projects are often conducted in collaboration with one of our multiple partners in the frame of national and international research projects. Our partners often include the European Space Agency, NASA Ames Research Center, DFKI, University of Luxembourg, Delft University of Technology, Tohoku University, EPFL, and many more.
How to apply
Please, send an email to srl@uma.es or directly to the person in charge of each project with the following: 1) your CV, 2) your bachelor’s or master’s transcripts (you can find it via UMA’s website), 3) title of the project you are applying for, and (optional) 4) a brief description of any relevant experience related to the project’s scope.
2026/2027 Projects
#1 Fast Vision-based Autonomous Navigation Across Extreme, Off-road Environments / Navegación Autónoma Rápida a Través de Entornos Extremos Basada en Visión Artificial - Unavailable
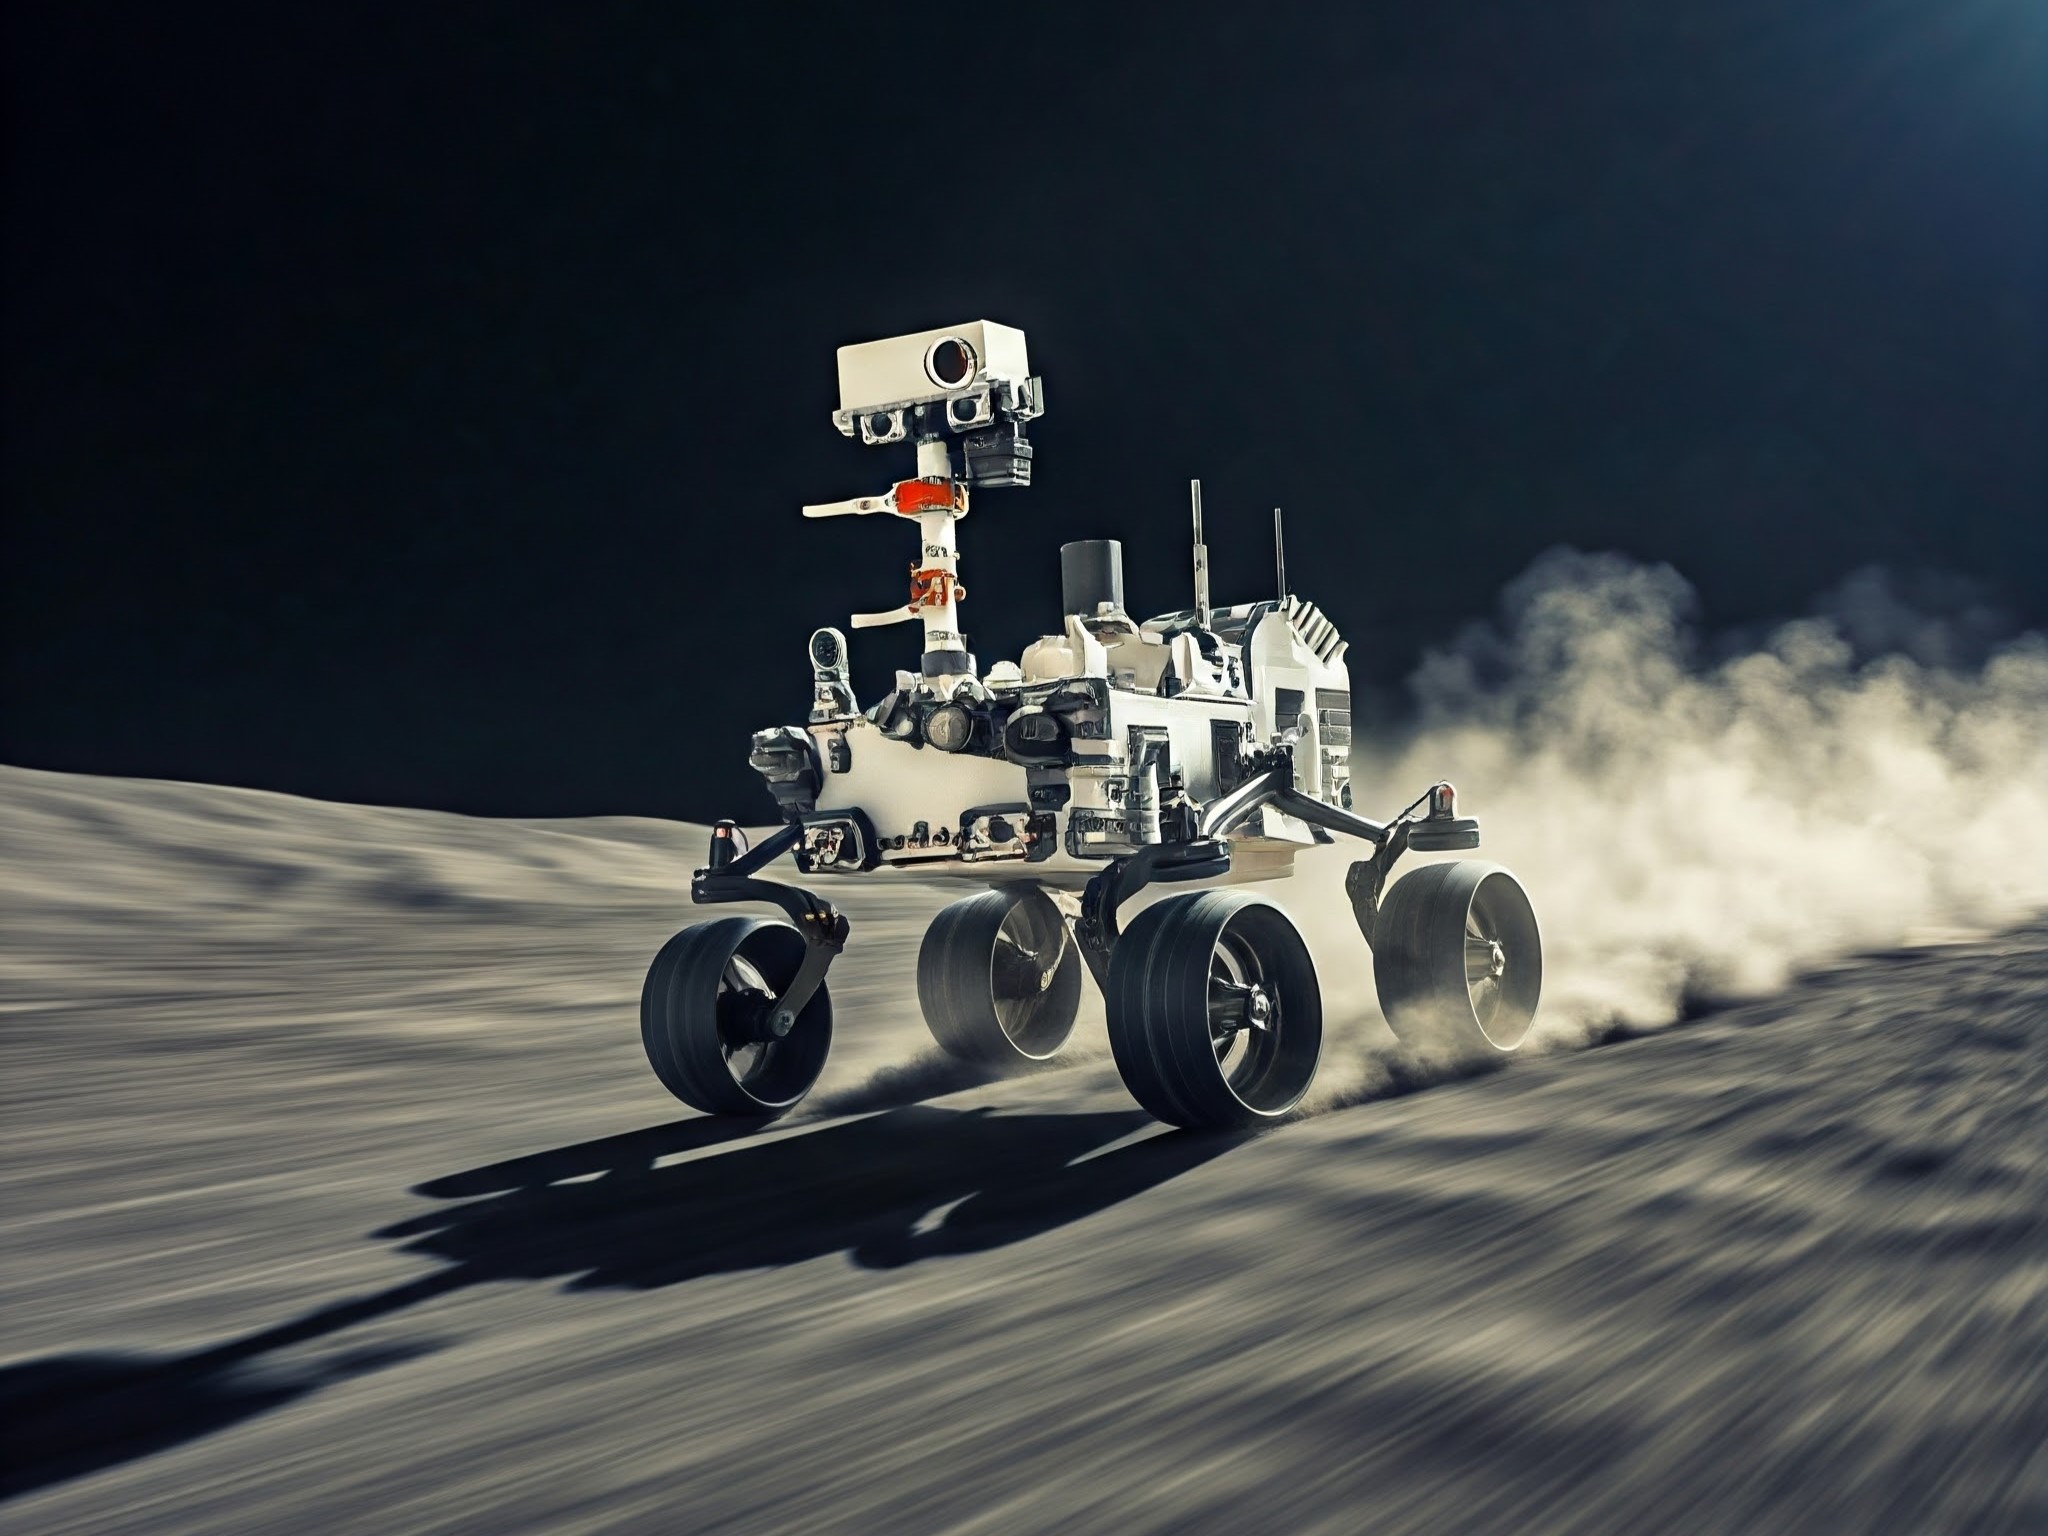 |
A number of upcoming planetary exploration missions demand speeds orders of magnitude greater than current operational rover speeds. In this project, you will evaluate, design, implement, and test a navigation pipeline aimed at estimating the position and orientation of a robot when traversing an unstructured environment at a speed of 1 m/s or faster across different times of the day (daytime vs nighttime). Performance will be compared against state-of-the-art solutions for off-road autonomous navigation and evaluated for potential implementation in space-grade processing units. An evaluation of the accuracy and precision of the pose estimates will be conducted. The goal is to benchmark this navigation pipeline as the foundation for future developments. Both conventional and learning-based approaches could be considered. Keywords: #navigation, #off-road, #speed, #planetary-exploration, #computer-vision |
#2 Relative Localization in Dark Environments Using Thermal Infrared (TIR) Cameras / Localización relativa en entornos oscuros empleando cámaras TIR - Unavailable
|
|
This project focuses on improving relative localization for mobile robots operating in low-visibility environments using thermal infrared (TIR) cameras. Relative localization estimates a robot’s change in position and orientation over time and is essential in applications such as space exploration, inspection, and rescue, where GPS is unavailable or unreliable.Conventional visual localization methods rely on detecting and tracking image keypoints using RGB cameras. However, these techniques often fail in environments with poor visibility, such as lunar lava tubes or smoke-filled disaster sites. Thermal cameras provide an alternative sensing modality, but existing keypoint-based localization methods are not well suited to thermal imagery because of its lower resolution, higher noise levels, and the presence of misleading thermal gradients caused by reflections and heat distortions. While some thermal-based localization approaches have shown promising results in structured indoor environments, they do not generalize well to unstructured outdoor settings such as caves or cliffs. The project therefore aims to evaluate different keypoint detection and description techniques on thermal images and adapt one of them to achieve accurate, robust, and computationally efficient relative localization in unstructured, low-visibility environments. Keywords: #navigation, #computer-vision, #multi-modal, #underground-exploration, #machine-learning, #advanced-sensing |

#3 Adaptive sensing-mode selection for single-photon vision / Selección adaptativa del modo de sensado para visión de fotón único - Unavailable
|
|
Single-photon avalanche diode (SPAD) cameras have the potential to operate in fundamentally different sensing modes, from conventional photon integration to high-dynamic-range or even event-based imaging. Each of these modes may be best suited to different scenes and tasks. Yet most systems commit to a single fixed mode, leaving much of the sensor's versatility unused. During autonomous operation, illumination, dynamic range, scene motion, and texture change continuously, so the optimal mode changes with them. In this project, you will evaluate, design, implement, and test an algorithm that autonomously selects the sensing mode from a classification of the environment and operational conditions. A central question is which image and scene properties are worth measuring and modelling to decide where to sit within the sensing-mode space; you will compare classical, learning-based, and hybrid selection strategies and characterize the resulting decision boundaries. The selector will be evaluated against a ground-truth notion of the optimal mode on simulated and, where feasible, real single-photon data. The goal is to benchmark this selector as a foundation for adaptive, software-defined single-photon sensing. Both conventional and learning-based approaches could be considered. Keywords: #adaptive-sensing, #computer-vision, #machine-learning, #planetary-exploration, #advanced-sensing |

#4 Motion compensation for vision-based navigation at high traverse speeds / Compensación del movimiento para navegación por visión a altas velocidades - Unavailable
|
|
A number of upcoming planetary and off-road missions demand traverse speeds 100x greater than current operational rovers. At high ego-motion, image sequences suffer from motion blur and large inter-frame displacements that degrade the feature correspondences on which vision-based navigation depends. This effect worsens in low light, where longer exposures are needed. Motion compensation, which aligns and merges successive frames to recover sharp, high-signal-to-noise imagery, is a key enabler under these conditions. In this project, you will evaluate, design, implement, and test motion-compensation techniques for image sequences captured under fast ego-motion by conventional or single-photon cameras, and assess their impact on downstream pose estimation. You will compare classical alignment-and-merging pipelines with learning-based and hybrid alternatives, and analyze which components actually drive performance. Evaluation will be conducted on simulated and real sequences with ground-truth motion, with attention to suitability for space-grade processing units. The goal is to benchmark motion compensation as a front-end enabler for fast vision-based navigation. Both conventional and learning-based approaches could be considered. Keywords: #navigation, #computer-vision, #motion-compensation, #speed, #machine-learning, #planetary-exploration |

#5 Locomotion concepts for the exploration of Icy Moon with microrovers / Conceptos de locomoción para la exploración de lunas heladas con microrovers- Available
|
|
Icy ocean worlds such as Saturn's moon Enceladus are among the most compelling places to search for life beyond Earth, but their surfaces are hostile to conventional rovers. On Enceladus, gravity is roughly 1% of Earth's, temperatures sit near 80 K, and the terrain near the active fractures is covered in fine plume-deposited ice whose mechanical behavior is largely unknown. How to traverse its surface is still an open question. In this project, you will review what is known about icy-moon surfaces and translate it into early models of their mechanical properties. Using these models, you will explore and compare candidate locomotion modes for a small robot accompanying a lander, such as hopping, rolling, legged, screw-propelled, or hybrid concepts, against criteria including traction, energy, thermal survival, and mass. You will then select the most promising concept and build an early bench prototype to test its core mechanism on terrestrial analogue materials,. Analytical models and simulation will be combined with hands-on testing. Keywords: #planetary-exploration, #robotics, #design, #prototyping, #locomotion, #icy-moons, #enceladus #terramechanics |
